

Haptic wearables enhance virtual reality experiences by delivering physical sensations that correspond to on-screen events, making the virtual world feel tangible rather than purely visual. When a user reaches out to touch a surface in VR and actually feels resistance, texture, or impact through a wearable device, the brain’s sense of presence increases dramatically. The sections below unpack how this works, what form factors exist, and where the technology still falls short.
What types of physical sensations can haptic wearables simulate in VR?
Haptic wearables in VR can simulate vibration, pressure, temperature changes, impact forces, and directional cues. The most commonly delivered sensations are vibrotactile — precise pulses and patterns that mimic contact, collision, or environmental feedback. More advanced systems layer pressure and squeeze effects on top of vibration to create a richer, more convincing tactile experience.
The range of sensations a wearable can produce depends heavily on the actuator technology inside it. The three dominant actuator types each have distinct characteristics:
- ERM (Eccentric Rotating Mass) motors produce broad, buzzing vibrations. They are inexpensive and widely used, but their frequency range is limited, making them less convincing for nuanced tactile events.
- LRA (Linear Resonant Actuator) motors deliver sharper, more localised vibrations with better frequency control. They respond faster than ERMs and are better suited to simulating distinct impacts or surface textures.
- Piezoelectric actuators offer the highest precision, with rapid response times and fine-grained control over intensity and frequency. They are the preferred choice when the goal is to simulate realistic tactile detail, though they are more complex to drive electronically.
Beyond vibration, some haptic systems use pneumatic or hydraulic mechanisms embedded in soft textiles to create squeeze and compression effects. These are particularly effective for simulating grip, weight, or the resistance of a physical object. Thermal feedback — warming or cooling elements in contact with the skin — remains a less mature but genuinely promising dimension of haptic VR simulation.
How does haptic feedback actually work inside a wearable device?
Haptic feedback in a wearable device works through a chain of components: a VR system sends an event signal, firmware translates that signal into a precise actuation pattern, and one or more actuators convert electrical energy into mechanical motion against the wearer’s skin. The entire loop from virtual event to physical sensation must happen within milliseconds to feel convincing.
The firmware layer is often underestimated in its importance. It is not enough to simply trigger a vibration motor when a collision occurs. The timing, intensity envelope, duration, and spatial distribution of the haptic signal all need to be engineered to match the perceptual expectation of the event. A punch landing on a glove should feel different from a surface texture being dragged across a fingertip. Achieving that distinction requires careful pattern design at the firmware level, not just hardware selection.
Placement of actuators across the body is equally critical. The skin’s sensitivity varies significantly by location — fingertips and lips are densely innervated, while the back and thighs are far less sensitive. A well-designed haptic wearable maps actuator positions to the body regions most relevant to the application and adjusts signal intensity accordingly. Getting this wrong produces sensations that feel generic or unconvincing, undermining the very immersion the system is meant to create.
Power management is another practical constraint. Running multiple actuators simultaneously draws significant current, and battery life in wearable form factors is always limited. Efficient firmware that sequences and prioritises haptic events — rather than firing all actuators at once — extends runtime without sacrificing the quality of the experience.
What’s the difference between haptic gloves, vests, and full-body suits for VR?
Haptic gloves focus feedback on the hands and fingers, vests target the torso for impact and environmental cues, and full-body suits distribute tactile sensation across the entire body surface. Each form factor serves a different use case, and the right choice depends on what the VR application needs the user to feel and where.
Haptic gloves
Gloves are the most technically demanding haptic form factor because the hands are the primary interface in most VR interactions. The fingertips have the highest density of mechanoreceptors in the body, meaning users will immediately notice if the feedback feels imprecise or delayed. High-quality haptic gloves use LRA or piezo actuators at each fingertip and often incorporate force-feedback mechanisms — tendons or pneumatic bladders — to simulate the resistance of gripping an object. The challenge is delivering this level of fidelity in a device light enough to wear during extended sessions without fatiguing the hand.
Haptic vests
Vests are better suited to applications where environmental feedback matters more than fine manipulation — combat simulations, immersive gaming, or training scenarios where the user needs to feel impacts, directional cues, or environmental conditions across the torso. The larger surface area of the chest and back allows for more actuators spread across a wider zone, enabling spatial effects such as a bullet impact on the left shoulder or rain falling across the upper back. Vests are generally easier to integrate with VR systems than gloves because the feedback requirements are less granular.
Full-body haptic suits
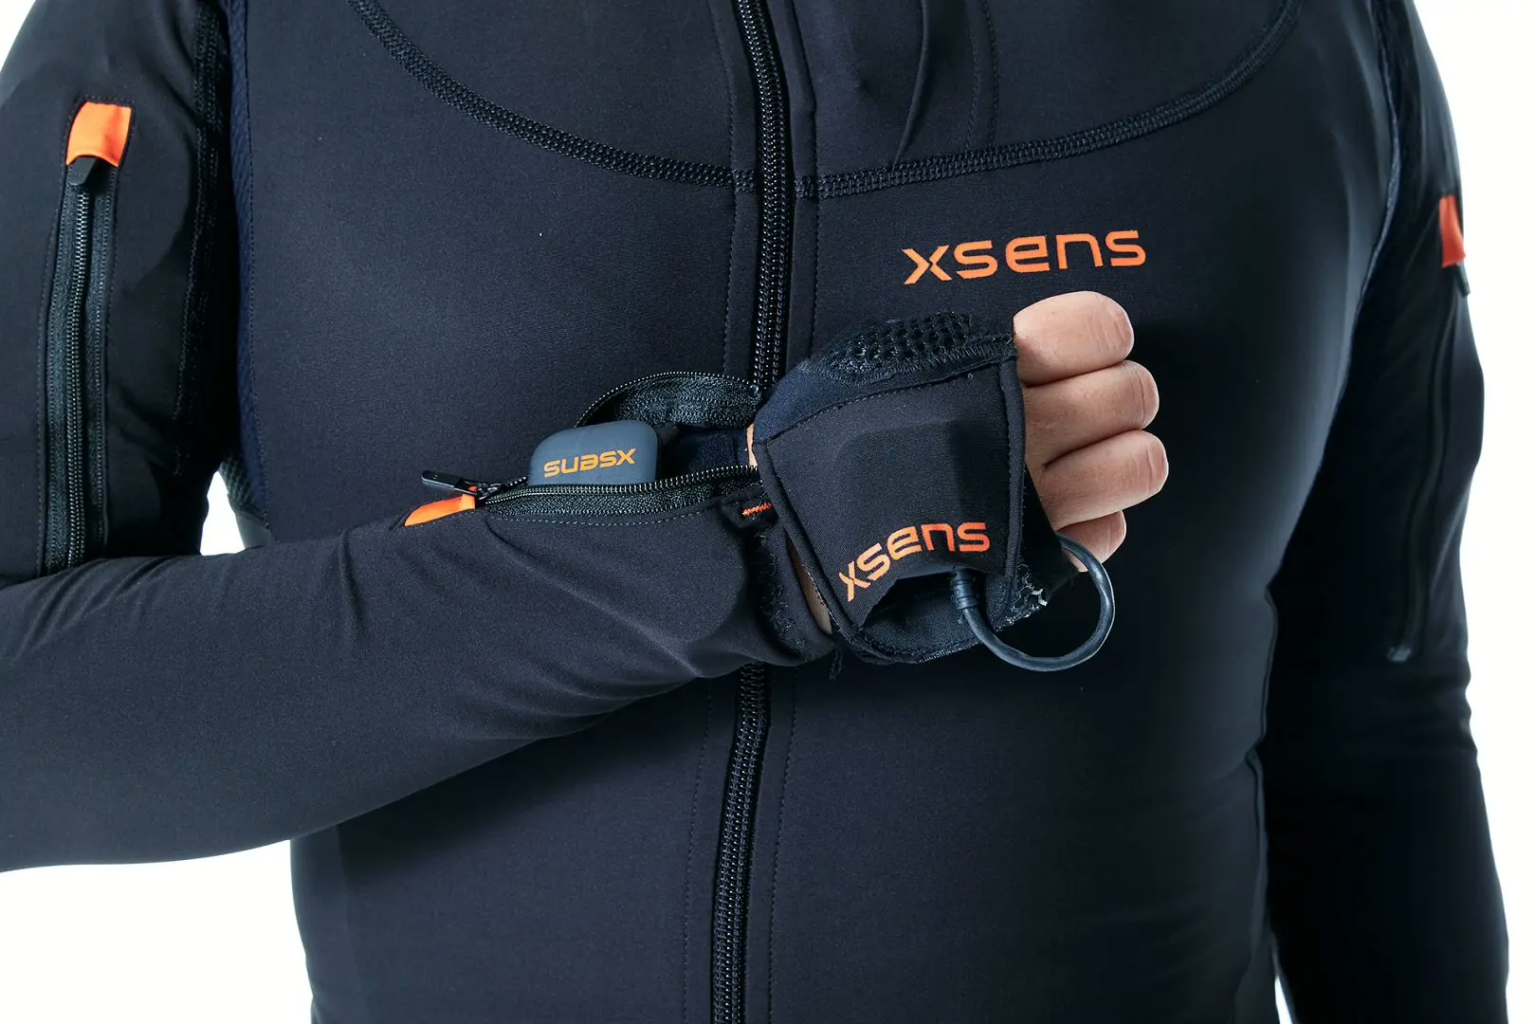
Full-body suits extend coverage to the arms, legs, and sometimes the feet, creating the most comprehensive haptic experience available. They are used in high-end training simulations, location-based VR installations, and research environments. The engineering complexity increases substantially — coordinating dozens of actuators, managing heat generated by electronics against the skin, and ensuring the garment remains comfortable and flexible during movement all become significant design challenges. Textile integration expertise becomes essential at this scale, as rigid electronics embedded in inflexible substrates will restrict movement and cause discomfort within minutes.
How do haptic wearables reduce simulation sickness in VR?
Haptic wearables can reduce simulation sickness by providing physical sensory input that aligns with the visual motion a user sees in VR. Simulation sickness occurs primarily when the visual system perceives movement that the vestibular system and proprioceptive senses do not confirm. Adding tactile and vibrotactile cues that correspond to on-screen events helps close that sensory gap, reducing the conflict that triggers nausea and disorientation.
The mechanism is rooted in multisensory integration. The brain continuously reconciles information from multiple sensory channels to construct a coherent model of the body’s position and movement. In standard VR with no haptic feedback, visual motion signals arrive without any corresponding physical sensation, creating a mismatch the brain interprets as potentially dangerous. Haptic cues — even subtle vibrations signalling footsteps, surface contact, or acceleration — give the brain additional data points that make the virtual experience feel more physically grounded.
Directional haptic feedback is particularly useful in this context. A wearable that delivers a gentle pressure cue on the side of the torso when the user turns in VR gives the vestibular system a physical correlate for the rotational motion seen on screen. This approach has been explored in navigation contexts — including directional haptic belts designed for hands-free situational awareness — and the same principle applies to VR comfort. The goal is not to perfectly replicate every physical sensation, but to provide enough congruent feedback that the sensory systems stop conflicting with each other.
Which VR applications benefit most from haptic wearable integration?
The VR applications that benefit most from haptic wearables are those where physical feedback is operationally meaningful — not just immersive, but functionally important. These include surgical and clinical training, military and defence simulation, industrial skills training, rehabilitation, and high-fidelity sports performance analysis.
In surgical and medical training, haptic feedback allows trainees to feel tissue resistance, instrument pressure, and the subtle tactile cues that experienced surgeons rely on. Simulating these sensations accurately accelerates skill development and reduces the gap between simulation performance and real-world competence. The stakes are high enough that the additional complexity and cost of haptic integration is clearly justified.
In military and defence simulation, haptic wearables replicate the physical environment of the battlefield — directional alerts, impact feedback, and environmental cues — without exposing personnel to real risk. The Mission Navigation Belt developed for the Royal Netherlands Army demonstrates how haptic feedback can deliver mission-critical information silently and without requiring the user to divert eyes or hands. That same logic applies directly to VR-based combat and tactical training.
In rehabilitation, haptic wearables in VR create engaging, measurable therapy environments for patients recovering from stroke, injury, or neurological conditions. The combination of visual feedback in VR and physical sensation from a wearable can support motor relearning in ways that neither modality achieves alone.
Industrial and skills training — from heavy equipment operation to complex assembly procedures — benefits from haptic VR because trainees can practice high-risk procedures with physical feedback that mirrors real-world consequences. This reduces training time and improves retention compared to purely visual simulation.
What are the current technical limitations of haptic wearables in VR?
The current technical limitations of haptic wearables in VR include limited actuator resolution, battery constraints, latency challenges, thermal management issues, and the difficulty of simulating complex sensations like texture and temperature convincingly. These are not insurmountable, but they represent genuine engineering problems that require specialist expertise to navigate.
Actuator resolution is one of the most persistent constraints. The human hand alone contains thousands of mechanoreceptors capable of detecting extremely fine spatial and temporal detail. No current wearable can match that density with physical actuators at a price point or form factor suitable for widespread use. The result is that haptic feedback in VR remains an approximation — good enough to enhance immersion, but not yet capable of reproducing the full fidelity of physical touch.
Battery life limits how long a haptic wearable can operate in a VR session. Running multiple actuators continuously is power-intensive, and the compact form factors required for comfortable wearables constrain battery size. Firmware-level optimisation — sequencing actuations intelligently and avoiding unnecessary simultaneous triggers — can extend runtime significantly, but this requires careful system-level engineering rather than simply choosing a larger battery.
Latency between a VR event and the corresponding haptic sensation must remain below the threshold of perceptual detection, typically around 20 milliseconds. Above that threshold, users notice the disconnect, which breaks immersion rather than enhancing it. Achieving low latency requires tight integration between the VR platform, the haptic controller, and the wearable’s firmware — a challenge that grows as the number of actuators and the complexity of the haptic patterns increase.
Thermal management becomes a real problem in full-body suits and high-actuator-density garments. Electronics generate heat, and heat trapped against the skin during physical activity causes discomfort quickly. Textile design and electronics layout must account for breathability and heat dissipation from the earliest stages of development.
Simulating complex sensations — fine texture, temperature gradients, wetness — remains largely unsolved at a commercial scale. Current systems can approximate these sensations with vibrotactile patterns, but the gap between approximation and genuine perceptual realism is still significant.
How Elitac Wearables helps with haptic VR wearable development
If you are developing a haptic wearable for a VR application — whether for medical training, defence simulation, rehabilitation, or industrial skills development — the technical complexity described above is not theoretical. It is the daily reality of development teams trying to deliver something that actually works on a real body, in real conditions, within a real budget.
Elitac Wearables brings together the full set of disciplines that haptic VR wearable development demands, under one roof:
- Actuator selection expertise across ERM, LRA, and piezo technologies, matched to your application’s fidelity requirements and form factor constraints
- Firmware-level haptic pattern design using TacOS, Elitac’s proprietary operating system built specifically for wearable haptic systems
- Electronics-textile integration for garments that remain flexible, comfortable, and manufacturable — not just functional in a lab
- Battery and power optimisation to extend session life without increasing device size
- Human factors and UX to ensure the haptic experience actually serves the end user’s needs, not just the spec sheet
- Certification guidance for medical or defence applications that require MDR compliance or military standards
Elitac works as an extension of your team, not a black-box vendor. Whether you are at the concept stage or stuck between prototype and production, the starting point is a direct conversation about your specific challenge. Reach out to Elitac Wearables to discuss your project and find out what the right haptic approach looks like for your application.
Related Articles
- How do haptic feedback wearables support remote collaboration?
- What does post-launch wearable product support and iteration actually cost?
- What does a wearable product development contract actually need to cover?
- How do medical-grade wearables differ from consumer wearables in development?
- What is the cost of developing a wearable product from scratch?