
Haptic feedback adds a real but manageable load to a wearable’s battery life. A single actuator typically draws around 50 to 500 milliwatts while it is running, but it only runs in short bursts. How much battery it actually costs depends on the actuator type, how often and how long it fires, how well it is driven, and how well it is coupled to the body. In most alert-based wearables, haptics are a minor energy consumer. In devices where touch is the main output, such as a navigation belt, they can be the largest one.
How much power does haptic feedback actually consume?
A small LRA typically draws around 100 to 200 milliwatts while vibrating. A coin-type ERM motor draws roughly 200 to 300 milliwatts, and larger ERMs can exceed 500 milliwatts at full drive. Piezo actuators vary widely, because their power depends on drive voltage, frequency and the driver electronics (more on that below).
Peak power alone says little. What matters is the energy used per haptic event, multiplied by the number of events. A simple example for an alert-based wearable:
- An alert of 150 milliwatts lasting 0.1 seconds uses 15 millijoules.
- One hundred alerts a day add up to 1.5 joules.
- A small 200 mAh, 3.7 V wearable battery stores about 2,660 joules, so those alerts use well under 0.1% of a full charge.
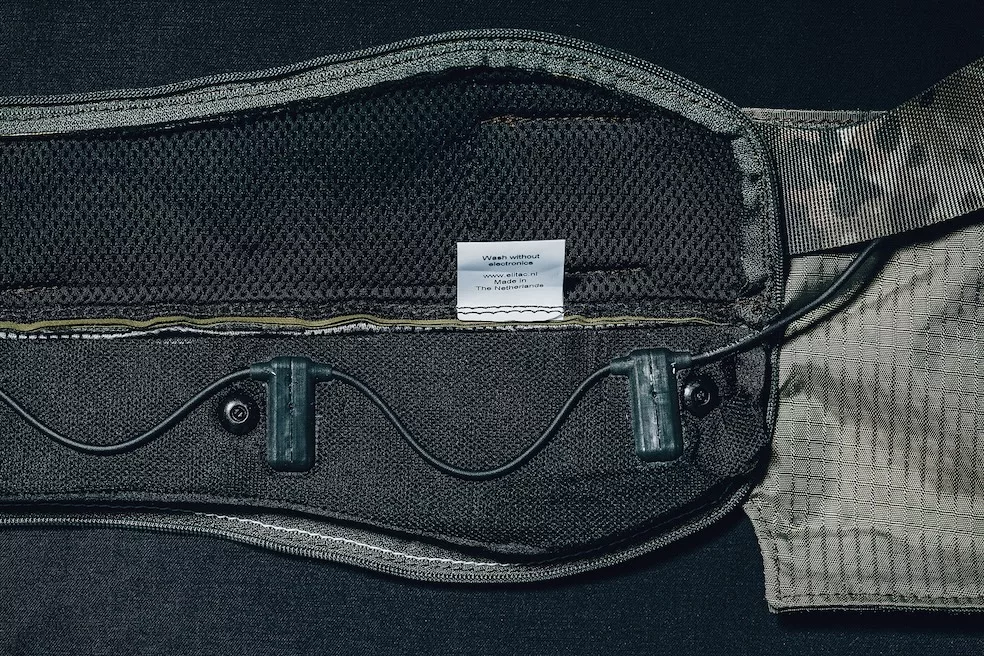
Now compare a haptic-first device. A navigation wearable like the Mission Navigation Belt, designed for military use, gives directional cues throughout a mission. If a single 150 milliwatt actuator is active a quarter of the time during an eight-hour mission, it uses roughly 1,100 joules, hundreds of times more than the alert example. In a device like this, haptics can become the biggest energy consumer, and pattern design and timing matter as much as the actuator hardware itself.
Which haptic actuator type is most energy efficient?
There is no single winner. LRAs (Linear Resonant Actuators) are usually the most efficient choice for simple vibration alerts, ERM (Eccentric Rotating Mass) motors are typically the least efficient, and piezo actuators can be very efficient or quite power-hungry depending on how they are driven. Each type also comes with trade-offs in feel, response time, cost and integration complexity.
ERM motors
ERM motors are the most common haptic actuator in consumer electronics. They are cheap and easy to drive. Their downside is efficiency: energy is lost in spinning the motor up at every event, in friction in the brushes and bearings, and in vibration that never reaches the skin. Start-up current can be two to three times the running current. ERMs are also slow, typically taking around 40 to 80 milliseconds to reach full vibration, which limits the precision of feedback patterns. For professional or medical wearables where battery life and feedback quality both matter, they are rarely the best choice despite their low price.
LRA actuators
LRAs move a small mass on a spring at a fixed resonant frequency, usually somewhere between about 150 and 250 Hz. Conveniently, that is close to the range where human skin is most sensitive to vibration. Driven at resonance, LRAs deliver more vibration per milliwatt than ERMs and respond faster, typically within about 10 to 30 milliseconds.
The catch is that their resonance is narrow, and it moves. Temperature, ageing, mounting and especially contact with the body (skin, strap tension, clothing) all shift the resonant frequency. A driver with automatic resonance tracking follows these shifts. A fixed-frequency drive can lose much of the LRA’s efficiency advantage as soon as the device is worn.
Piezo actuators
Piezo actuators respond extremely fast, often within a millisecond or two, and produce sharp, precise sensations in a very thin package. Their current is low, but they need high drive voltages, often 50 to 200 volts, generated by a dedicated driver. Because a piezo behaves like a capacitor that is charged and discharged on every vibration cycle, its power use rises with voltage and frequency, and the driver adds its own losses. With a driver that recovers this energy, piezos can be very efficient. Without one, they can use more energy per event than an LRA. Choose piezo for speed, precision and form factor, and verify efficiency on the actual driver design.
What factors make haptic feedback drain the battery faster?
Haptic feedback drains a battery faster when actuators are driven harder, longer or more often than the use case needs, when they are poorly coupled to the body, or when the firmware leaves the haptic circuit active between events. These are mostly system-level issues, and they are among the most common causes of battery underperformance discovered late in wearable development.
The most important factors are:
- Feedback frequency: Continuous or near-continuous output drains far faster than short, targeted alerts. Checking whether every haptic event is truly needed is often the first place to recover battery life.
- Drive intensity: Power rises roughly with the square of the drive voltage. Reducing the drive by about 30% can roughly halve the power, while users notice a much smaller drop in strength. Calibrate to the lowest level that is still clearly felt at each body location.
- Pattern duration: Longer patterns use more energy per event. Short, well-designed patterns that remain clear and meaningful are almost always better for battery life.
- Body location and coupling: Some body areas are less sensitive than others; the torso, for example, typically needs more drive than the wrist. A loose strap or a soft enclosure absorbs vibration before it reaches the skin, so the actuator has to work harder.
- Idle behaviour: A haptic driver left in an active idle state can draw hundreds of microamps continuously, compared with a few microamps or less in shutdown. Over days of use, that adds up.
- Actuator mismatch: An oversized actuator, or a high-power ERM where a small LRA would do, draws more power than the feedback quality justifies.
- Peak current: For small batteries, the risk is not only total energy but short current peaks. ERM start-up and LRA overdrive pulses can make the battery voltage dip far enough to cause resets, especially in the cold or at low charge. Coin cells are particularly sensitive to this.
How can haptic feedback be optimised to extend battery life?
Battery life in a haptic wearable is a system-level challenge. The best results come from looking at actuator choice, drive electronics, mechanics, firmware and pattern design together, rather than one at a time.
In practice, the most effective steps are:
- Choose the right actuator: Match actuator type and size to the actual feedback need. A small, efficient actuator at moderate drive often outperforms a larger one that is turned down.
- Keep LRAs at resonance automatically: Use a driver with resonance tracking, so efficiency holds up on a real body and not only on the bench.
- Calibrate drive levels: Set voltage and waveform to the lowest level that is clearly felt at the intended body location.
- Improve mechanical coupling: Place actuators on sensitive body areas, keep good skin contact and avoid enclosures that absorb vibration. This saves energy without any electronic change.
- Power down between events: Firmware should put the haptic driver into shutdown immediately after each event, unless the next event follows within a very short time.
- Shorten and reduce patterns: Remove redundant alerts, shorten patterns where possible, and use visual or audio cues where they make more sense.
- Check peak currents: Make sure the battery and power supply can handle haptic peaks under worst-case conditions, such as cold temperatures and a low state of charge.
- Measure under real use: Profile energy per event and per subsystem during realistic use, not only at fixed intervals on the bench.
Teams that treat battery underperformance as a component problem often reach for a bigger battery. That typically triggers a cascade of consequences: a larger enclosure, new tooling, delays and higher cost. Optimising firmware, hardware and pattern design across the whole system often recovers a meaningful share of battery life without changing the form factor. How much depends on where the energy actually goes. In haptic-first devices, the haptic subsystem offers the biggest gains; in other wearables, most savings usually come from the radio and sensors.
Does haptic feedback affect battery life more than other wearable features?
In most wearables, no. The display (especially on smartwatches), wireless communication such as continuous Bluetooth streaming, and always-on sensing such as optical heart rate or high-rate motion sensing usually use more energy over a full day than haptic alerts. Haptics often get the blame because every vibration is noticeable and easy to link to a specific interaction.
The picture changes when haptics are the main output channel. In a navigation belt or a tactile alert system for people with hearing loss, haptics can become the largest energy consumer. In a device where vibration is only a short confirmation next to a display and a Bluetooth connection, it is usually a small share of the total.
What makes haptics worth attention is that they are easy to optimise. Radio behaviour is often limited by protocol requirements, and sensor sampling rates are set by accuracy needs. Haptic patterns, intensity and timing, by contrast, can usually be adjusted substantially without affecting the core function of the product.
The practical advice for development teams: measure every subsystem before deciding that haptics are the problem. Battery shortfalls blamed on haptics are often caused by a radio that never enters sleep mode or a sensor that samples far faster than necessary.
How Elitac Wearables helps with haptic feedback battery optimisation
Battery underperformance is one of the most common challenges development teams bring to Elitac Wearables, often late in the project, when timelines are tight and a full redesign is not an option. The approach is always the same: treat it as a system-level problem, not a component problem, and optimise across every layer before recommending any hardware change.
For product leaders and CTOs navigating this challenge, Elitac Wearables offers:
- Actuator selection and sizing: Matching ERM, LRA or piezo actuators to the feedback requirements, body location and power budget of the application
- Firmware-level power management: Using the proprietary TacOS platform to implement power gating, resonance-matched drive signals and idle state management across the haptic subsystem
- Haptic pattern design: Designing vibration patterns that are clear and meaningful to end users at the lowest effective intensity and duration
- Full-system energy profiling: Identifying which subsystems (haptics, radio, sensing or processing) are actually responsible for battery shortfalls, so optimisation effort goes where it has the most impact
- End-to-end integration: Hardware, firmware, mechanical and textile integration under one roof, including actuator placement and body coupling, so power inefficiencies do not fall between the cracks
If haptic feedback battery life is threatening your product’s launch timeline or field performance, the right starting point is a structured audit, not a larger battery. Get in touch with Elitac Wearables to find out where the energy is actually going and what it takes to resolve it.
Related Articles
- How do you identify missing documentation in an inherited wearable prototype?
- How do you turn a university wearable prototype into a commercial development project?
- What are the ethical concerns around soldier surveillance via wearables?
- What role do wearables play in special forces operations?
- How do wearables improve training outcomes for defence personnel?