
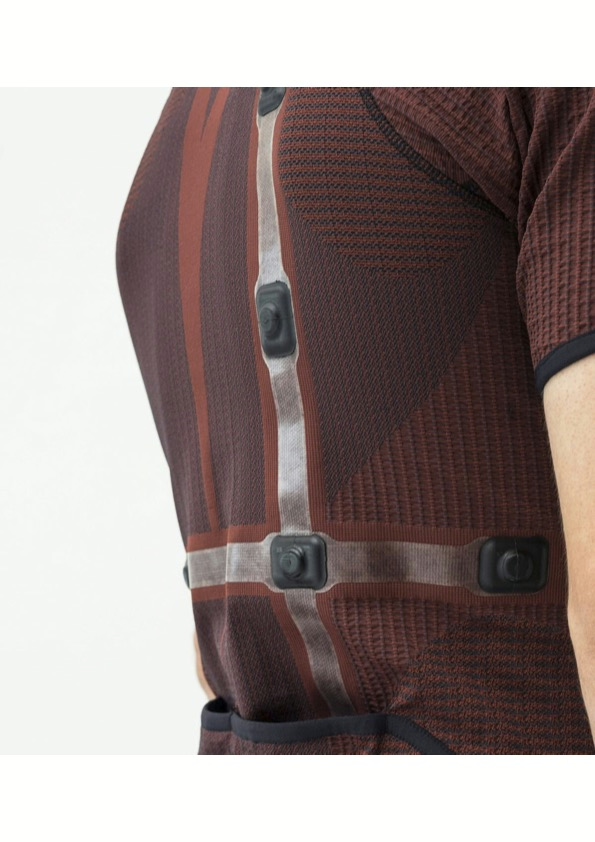
Haptic feedback wearables rely on a combination of sensors to detect what the body is doing and translate that information into meaningful tactile signals. The most common sensor types include inertial measurement units (IMUs), pressure and force sensors, and electromyography (EMG) sensors, each suited to different applications and triggering conditions. Understanding which sensors belong in your device is one of the most consequential decisions in any haptic wearable development project.
How do sensors trigger haptic feedback in wearables?
Sensors in haptic wearables act as the input layer: they continuously measure physical data from the body or environment, and when that data crosses a defined threshold or pattern, the system triggers an actuator to deliver tactile output. The sensor does not produce the haptic signal itself; it informs the firmware logic that decides when, where, and how strongly to activate the haptic actuator.
In practice, this means the sensor and actuator are connected through a processing layer, typically a microcontroller running firmware that interprets incoming sensor data in real time. For example, in a balance rehabilitation wearable, a tilt sensor detects postural deviation, and the system responds with a directional vibration cue to prompt correction. In a navigation wearable, GPS or IMU data drives vibration patterns that guide the wearer without requiring visual attention.
The quality of this feedback loop depends on three things: the accuracy and sampling rate of the sensor, the intelligence of the firmware logic, and the responsiveness of the actuator. A poorly chosen sensor introduces noise or lag that makes haptic cues feel unpredictable or irrelevant. Getting this chain right is the core engineering challenge in any haptic feedback wearable device.
What are inertial measurement units and why are they common in haptic wearables?
An inertial measurement unit, or IMU, is a sensor that measures acceleration, angular velocity, and sometimes magnetic field orientation. IMUs are among the most widely used sensors in haptic wearables because they capture how the body moves in three-dimensional space, making them ideal for applications built around posture, balance, navigation, and gesture recognition.
IMUs typically combine an accelerometer, a gyroscope, and in nine-axis configurations, a magnetometer. Together, these components give the system a continuous picture of body position and movement. This makes them particularly valuable in wearable haptic systems where the feedback needs to respond to orientation rather than a simple on/off trigger.
In defence and military applications, IMUs are a natural fit for navigation wearables. The Mission Navigation Belt developed for the Royal Netherlands Army uses orientation data to deliver directional haptic cues, freeing soldiers from having to look at a screen in the field. In medical wearables designed to support balance disorder rehabilitation, IMUs detect subtle postural shifts and trigger corrective vibration patterns before a fall occurs.
IMUs are also relatively power-efficient and compact, which matters in body-worn devices where size and battery life are tightly constrained. Their broad availability and well-understood integration behaviour make them a default starting point for many haptic wearable development projects, though the firmware logic required to interpret their output reliably under real-world movement conditions is considerably more demanding than the hardware itself.
What role do pressure and force sensors play in haptic feedback systems?
Pressure and force sensors measure mechanical load applied to a surface, either from the environment or from the wearer’s body. In haptic wearable devices, they are used to detect contact events, loading patterns, or physical interaction that should trigger or modify tactile feedback. Common applications include insole-based gait analysis, grip monitoring in rehabilitation gloves, and load detection in industrial or sports wearables.
In gait analysis wearables, pressure sensors embedded in a shoe insole or sock can identify heel strike, toe-off, and weight distribution across the foot. This data can trigger haptic cues to correct walking patterns in post-stroke rehabilitation or guide athletic technique in real time. The sensor data is often combined with IMU data to build a richer picture of movement mechanics.
Force-sensitive resistors and capacitive pressure sensors are the two most common implementations in wearable contexts. Force-sensitive resistors are thin, flexible, and relatively inexpensive, which makes them compatible with textile integration. Capacitive sensors offer higher sensitivity and repeatability, which is important in clinical or research-grade applications where measurement accuracy is critical.
One practical challenge with pressure sensors in wearables is placement stability. A sensor that shifts position on the body between wearings will produce inconsistent readings, which undermines the reliability of the haptic feedback it triggers. Securing sensors within a textile structure without restricting comfort or movement is a textile integration problem as much as an electronics problem, and it requires both disciplines to be addressed together from the start of development.
How do EMG sensors contribute to haptic wearable functionality?
Electromyography (EMG) sensors detect the electrical signals produced by muscles when they contract. In haptic wearables, EMG sensors enable the system to respond to the wearer’s intended movement or muscular effort rather than just their position or applied force. This makes them particularly valuable in prosthetics control, rehabilitation wearables, and human-machine interface applications where the device needs to anticipate or mirror the user’s motor intent.
In a rehabilitation context, EMG sensors placed over a target muscle group can detect activation patterns and trigger haptic feedback to reinforce correct muscle use or signal compensatory movement. In prosthetics, surface EMG signals from residual limb muscles are used to control prosthetic hand movements, with haptic feedback closing the sensory loop by providing the wearer with tactile information about grip force or contact.
The main engineering challenge with EMG in wearable devices is motion artefacts. When the wearer moves, the electrode-skin interface shifts, introducing electrical noise that can be misread as muscle activity. Dry electrodes, which do not require gel and are more compatible with textile integration, are particularly susceptible to this problem in high-movement conditions. Managing motion artefacts requires careful electrode placement, signal filtering at the firmware level, and often a combination of EMG with IMU data to distinguish genuine muscle signals from movement noise.
Integrating EMG electrodes into a textile substrate adds further complexity. The electrode material must maintain consistent skin contact across a range of body sizes and movement patterns, and the conductive pathways within the garment must not introduce electrical interference. These are solvable problems, but they require experience with both biosignal sensing and electronics-textile integration working in close coordination.
What other sensor types appear in advanced haptic wearables?
Beyond IMUs, pressure sensors, and EMG, advanced haptic wearable devices incorporate a range of additional sensor types depending on the application. These include electrodermal activity (EDA) sensors, photoplethysmography (PPG) sensors, temperature sensors, proximity sensors, and GPS modules, each adding a distinct layer of contextual awareness that can drive more nuanced haptic responses.
Physiological sensors: EDA and PPG
EDA sensors measure changes in skin conductance caused by sweat gland activity, which correlates with autonomic nervous system arousal. In stress monitoring or biofeedback wearables, EDA data can trigger calming haptic patterns when the system detects elevated arousal. PPG sensors, which measure blood volume pulse using light, are used for heart rate and heart rate variability monitoring. In sports or medical wearables, crossing a heart rate threshold can trigger a haptic alert without requiring the wearer to check a screen.
Environmental and positional sensors: temperature, proximity, and GPS
Temperature sensors can detect both skin temperature and ambient conditions, relevant in occupational safety wearables that monitor heat stress. Proximity sensors detect the presence of nearby objects or surfaces, useful in industrial or navigation applications where collision avoidance matters. GPS modules provide absolute positional data, which, combined with IMU data, creates a robust navigation input for directional haptic guidance systems. The Mission Navigation Belt is a direct example of GPS and orientation data driving a haptic output layer in a demanding real-world environment.
Which sensors are best suited for a haptic wearable development project?
The right sensors for a haptic wearable project depend entirely on what the device needs to detect and respond to. There is no universal sensor stack. The decision should be driven by the triggering condition, the application environment, the required accuracy, and the constraints of the wearable form factor including power budget, size, and washability requirements.
A useful way to approach sensor selection is to start with the trigger question: what physical event or state should cause the haptic feedback to activate? If the answer is body orientation or movement, IMUs are the natural starting point. If it is muscular effort or motor intent, EMG becomes relevant. If it is contact or load, pressure or force sensors are appropriate. Many real-world devices combine two or more sensor types to build a more reliable triggering model, particularly where a single sensor type would be vulnerable to noise or false positives.
Beyond the triggering logic, sensor selection must account for integration constraints. A sensor that performs well in a lab bench test may behave very differently when embedded in a textile, worn against moving skin, and subjected to sweat, wash cycles, and variable contact pressure. These real-world conditions change the performance profile significantly, and they need to be tested early in the development process rather than discovered late.
Power consumption is another decisive factor. Sensors that run continuously at high sampling rates will drain a wearable battery quickly. Duty cycling, intelligent sampling strategies, and firmware-level power management can extend battery life substantially without sacrificing the responsiveness the haptic system needs. Treating sensor power draw as a system-level consideration from the start avoids the common trap of discovering a battery shortfall late in development when redesign is expensive.
How Elitac Wearables helps with sensor selection for haptic wearable devices
Choosing the right sensors for a haptic feedback wearable is rarely straightforward, and the consequences of a poor choice compound throughout development. At Elitac Wearables, sensor selection is treated as a system-level decision from the very first feasibility phase, not an isolated hardware choice. The team brings together hardware engineers, firmware developers, textile specialists, and biosignal experts to evaluate sensor options against the full set of real-world constraints your device will face.
- Application-driven sensor matching: We map your triggering requirements to the sensor types best suited to detect them reliably in a body-worn context, whether that is IMUs for orientation, EMG for muscular intent, or pressure sensors for contact events.
- Motion artefact management: For biosignal sensors including EMG and EDA, we apply dry electrode selection strategies and firmware-level filtering to maintain signal quality under high-movement conditions.
- Textile integration expertise: With over a decade of experience embedding sensors into garments, we select and position sensors to maintain consistent skin contact across body sizes and movement patterns without compromising comfort or washability.
- Power budget optimisation: Sensor sampling strategies are designed in coordination with firmware and hardware to keep power consumption within your battery constraints, avoiding late-stage redesign.
- Full haptic system design: Sensor selection is always connected to actuator choice and firmware logic, so the entire input-to-output chain is optimised as one coherent system rather than assembled from separate decisions.
If you are at the stage of defining the sensor architecture for a haptic wearable, or if an existing design is producing unreliable feedback in real-world conditions, get in touch with the Elitac Wearables team. We will help you identify where the problem sits and what the right approach looks like for your specific application and constraints.
Related Articles
- How do medical-grade wearables differ from consumer wearables in development?
- What is the cost of developing a wearable product from scratch?
- How do you conduct user research for a wearable product?
- What are the stages of wearable product development?
- What role does firmware play in wearable product development?